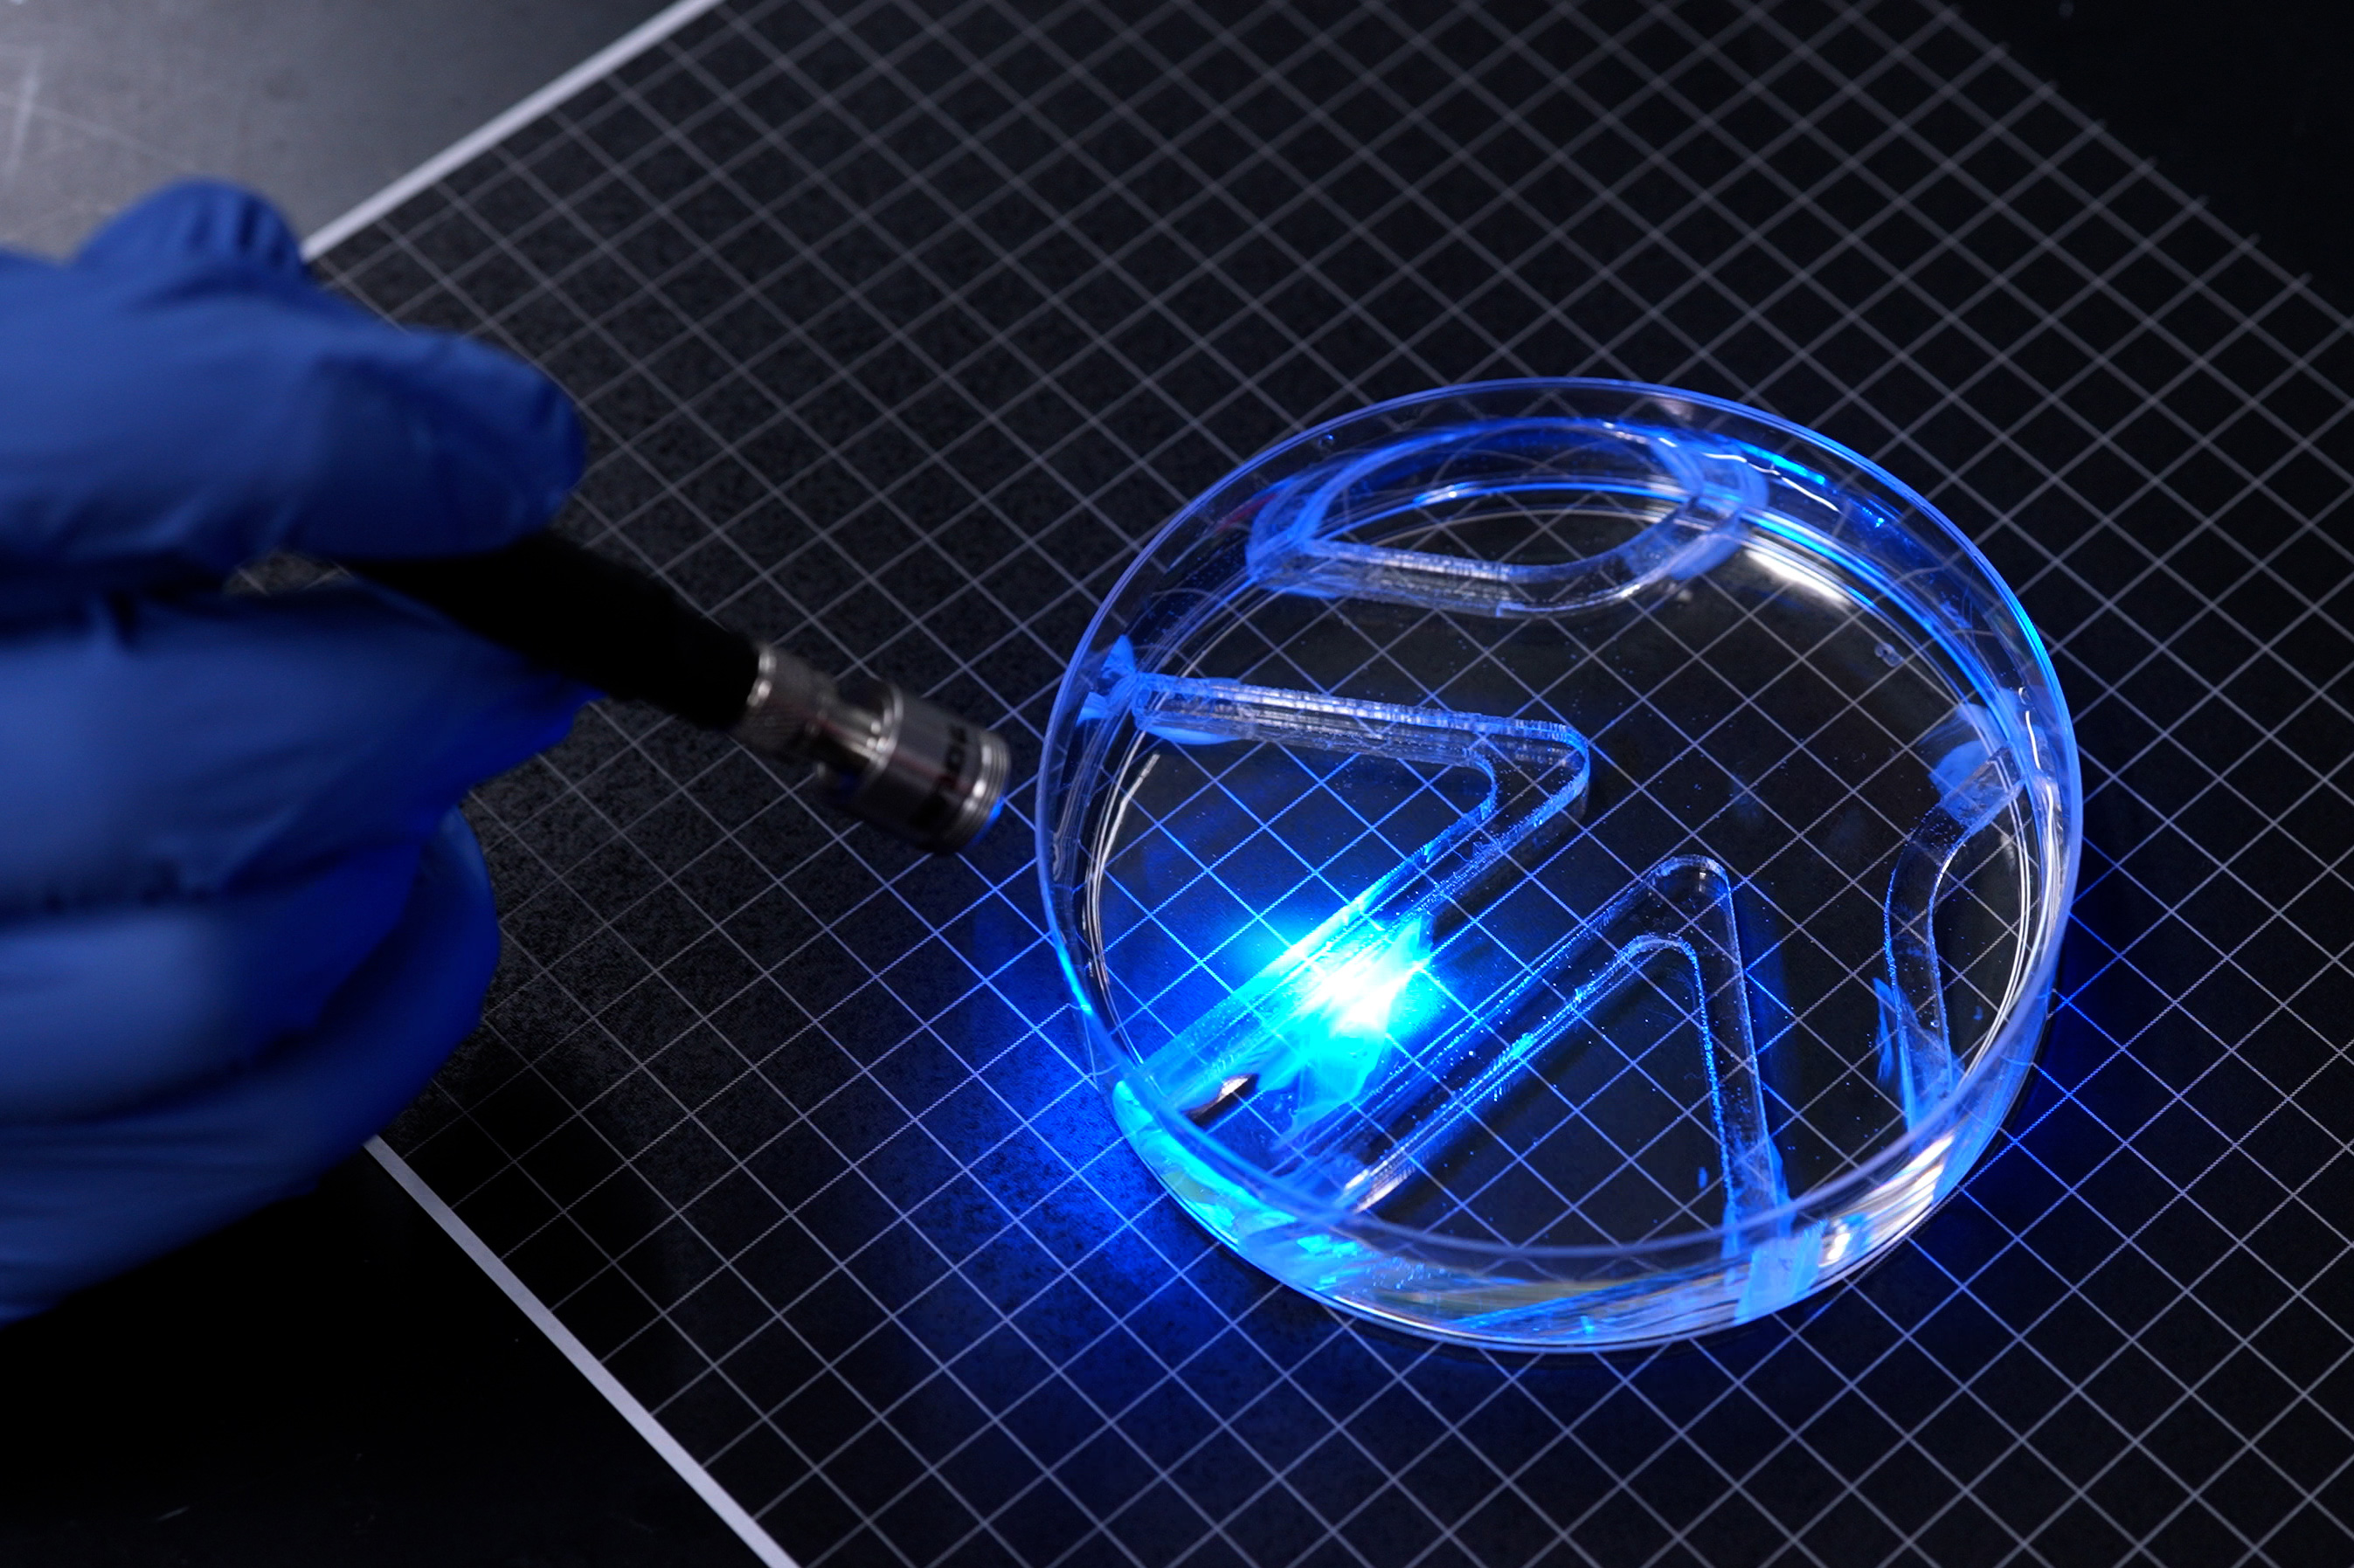
Instead of an electric motor, the experimental device uses two muscle-lined fins whose contraction can be controlled with light. The result is slow but remarkable: movement without a bulky jointed drivetrain. MIT published video of the demonstration in late September.
Action: watch the original demonstration and consider the design principle—distributed actuation—for future soft robotics or small maker projects.